DEXTER (ITER)
Because components of ITER fusion reactor may become contaminated should maintain to this as much as possible to remotely take place.
Challenge
Because components of fusion reactor ITER may be exposed to radiation and may be contaminated with toxic substances (such as tritium and beryllium), the maintenance of these components should take place at a distance as much as possible. This ‘Remote Handling’ usually takes place using master-slave techniques. These manipulators, consisting of a pair of robotic arms and a controller, should be designed so that positions and forces can be transmitted from operator to setting and vice versa as purely as possible.
Solution
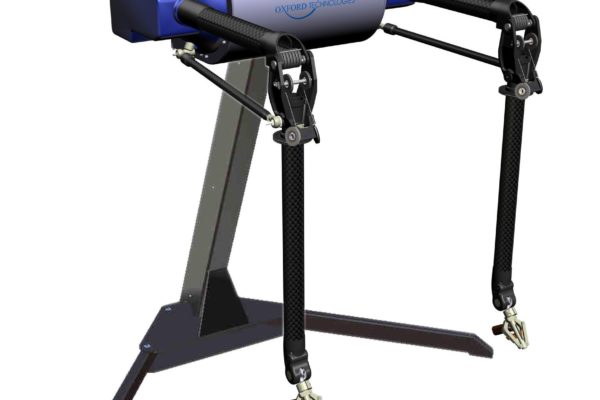
The starting point is the proven MASCOT technique, which has been used for over 10 years for full-scale remote handling on the JET fusion reactor. The end goal of the project is a single-arm manipulator which can be deployed as both master and slave.
Contribution HIT
Heemskerk Innovative Technology (HIT) and Oxford Technologies BV (OTBV) collaborate on the development of a next generation master-slave remote manipulator within the framework of the project DEXTER.